Sensors· IMU / motion
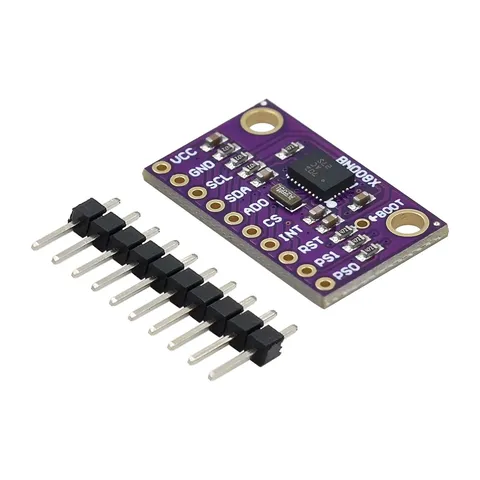
BNO085 / BNO086 9-axis fusion IMU
9-axis IMU with an on-chip Cortex-M0 running CEVA's fusion firmware; outputs ready rotation vectors.
Verdict. The easy route to stable orientation (head tracking, VR, robots). The BNO086 adds better interrupt handling; same price class.
Specs
| Output | quaternion, game/geomag rotation vector |
|---|---|
| Rate | up to 1 kHz (game RV) |
| Bus | I2C / SPI / UART-RVC |
| Heading accuracy | ~2° (calibrated) |
Prices
| AliExpress | €14.7 | GY-BNO085 generic board· from search results | |
| Botland | €30.9 | Adafruit 4754· from search results | |
| Botland | €48.5 | SparkFun BNO086 Qwiic· from search results |
- Fusion and calibration done on chip
- Stable game rotation vector
- UART-RVC mode needs no driver
- I2C clock stretching breaks on Raspberry Pi/ESP32
- Calibration lost on power cycle unless saved
- €15-50, far above raw IMUs
What people say liked
Liked for plug-and-play orientation; forum threads report I2C hangs and heading resets after power loss.
“We are experiencing issues with the BNO085 IMU providing inaccurate heading readings.” — SparkFun forum, 2024-06
“Everything gets reset when you remove power, this is normal.” — SparkFun forum, 2024-06
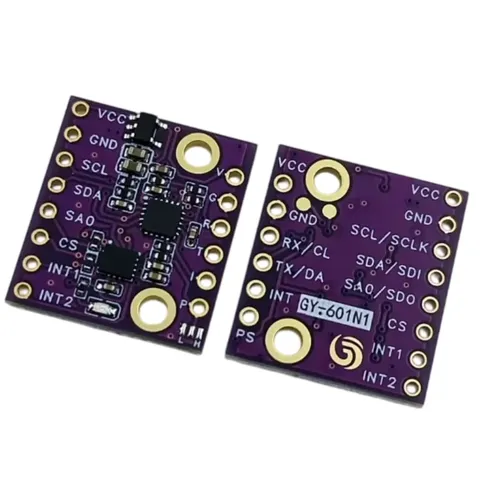 LSM6DSV16X 6-axis IMU (also LSM6DSOX)
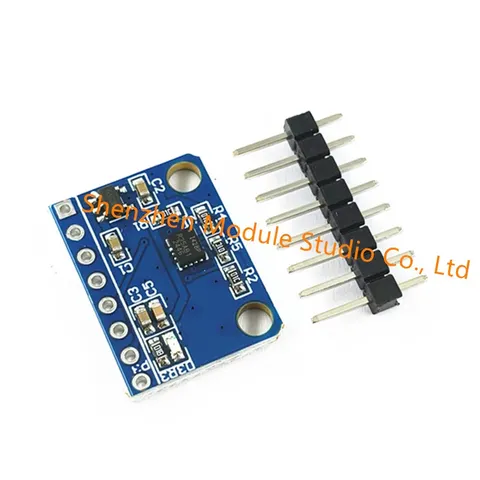 ICM-42688-P 6-axis IMU module